

Universal joint#
Block appearance in REPEAT VISION#
Joint (universal) clutch transmits the torque (see Fig. 1 below) to a load shaft located at a distance, or in case of misalignment of the drive and driven shafts.
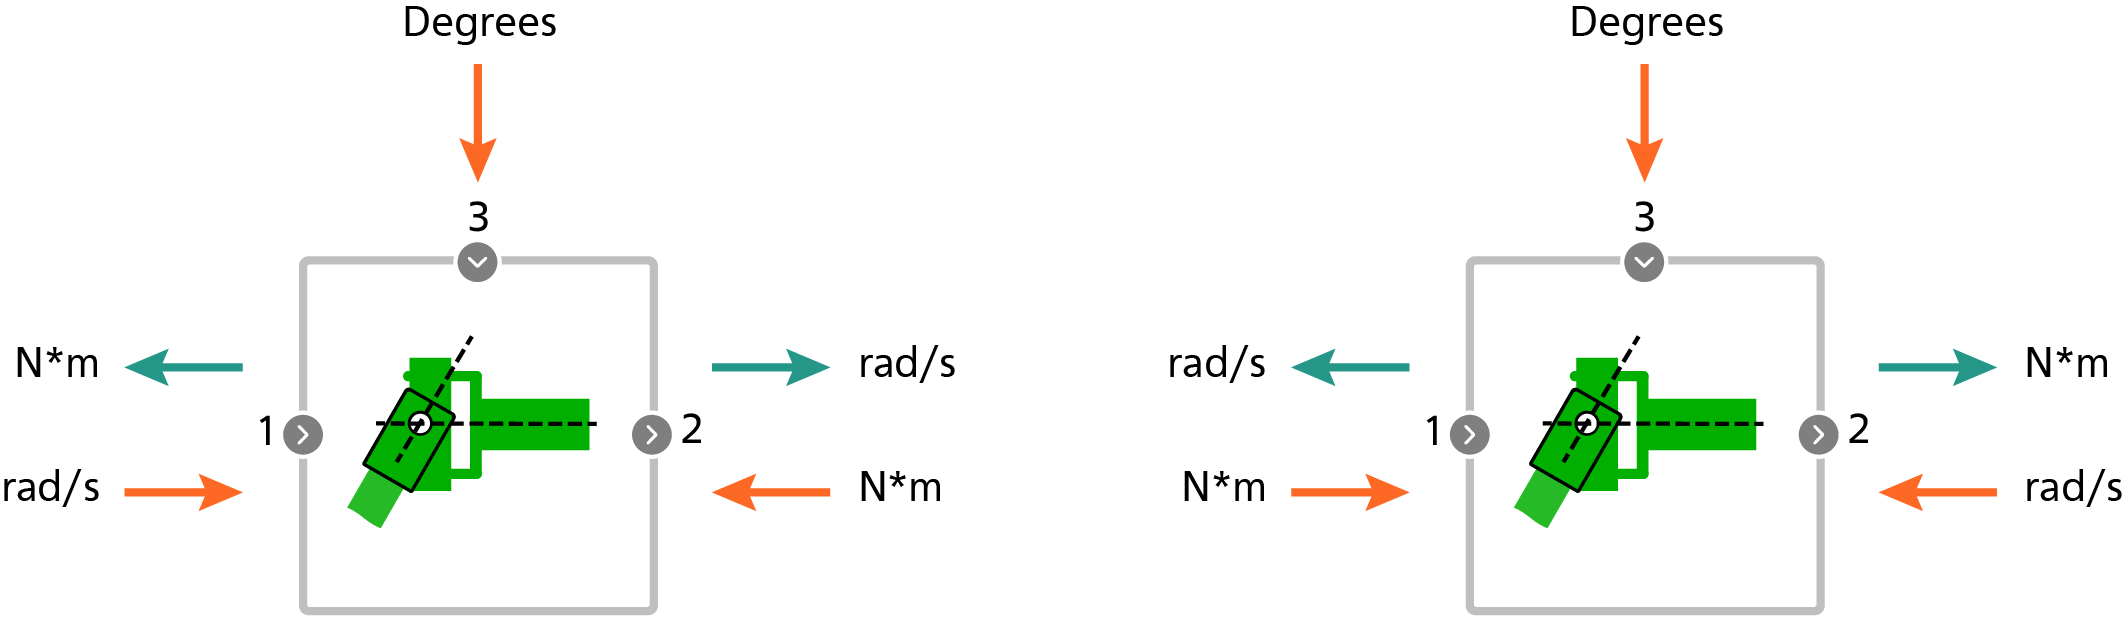
Fig. 1 External parameters#
The signal given to input 3 is the angle between the two connected shafts in degrees. When angular velocity is converted, the input 1 receives the angular velocity of the first shaft, and then the angular velocity of the second shaft is calculated with respect to the angular characteristics.
Velocity and torque conversion equations (1), (2):
The phase shift between two clutches connected in series is specified in parameters. The Shaft rotation angle property is used when more than two joint clutches are connected in series, in this parameter it is necessary to specify the sum of values of Shaft rotation angle and Phase difference between the shafts properties of the previous joint shaft.
As an example of the use of a joint clutch, consider a classic drive shaft of two clutches (see Fig. 2 below). The first clutch shall have all properties set to 0, the second clutch shall have the Phase difference between the shafts property set to 90 degrees. The transfer of the shear angle to both clutches ensures the damping of the angular velocity fluctuations generated at the first clutch.
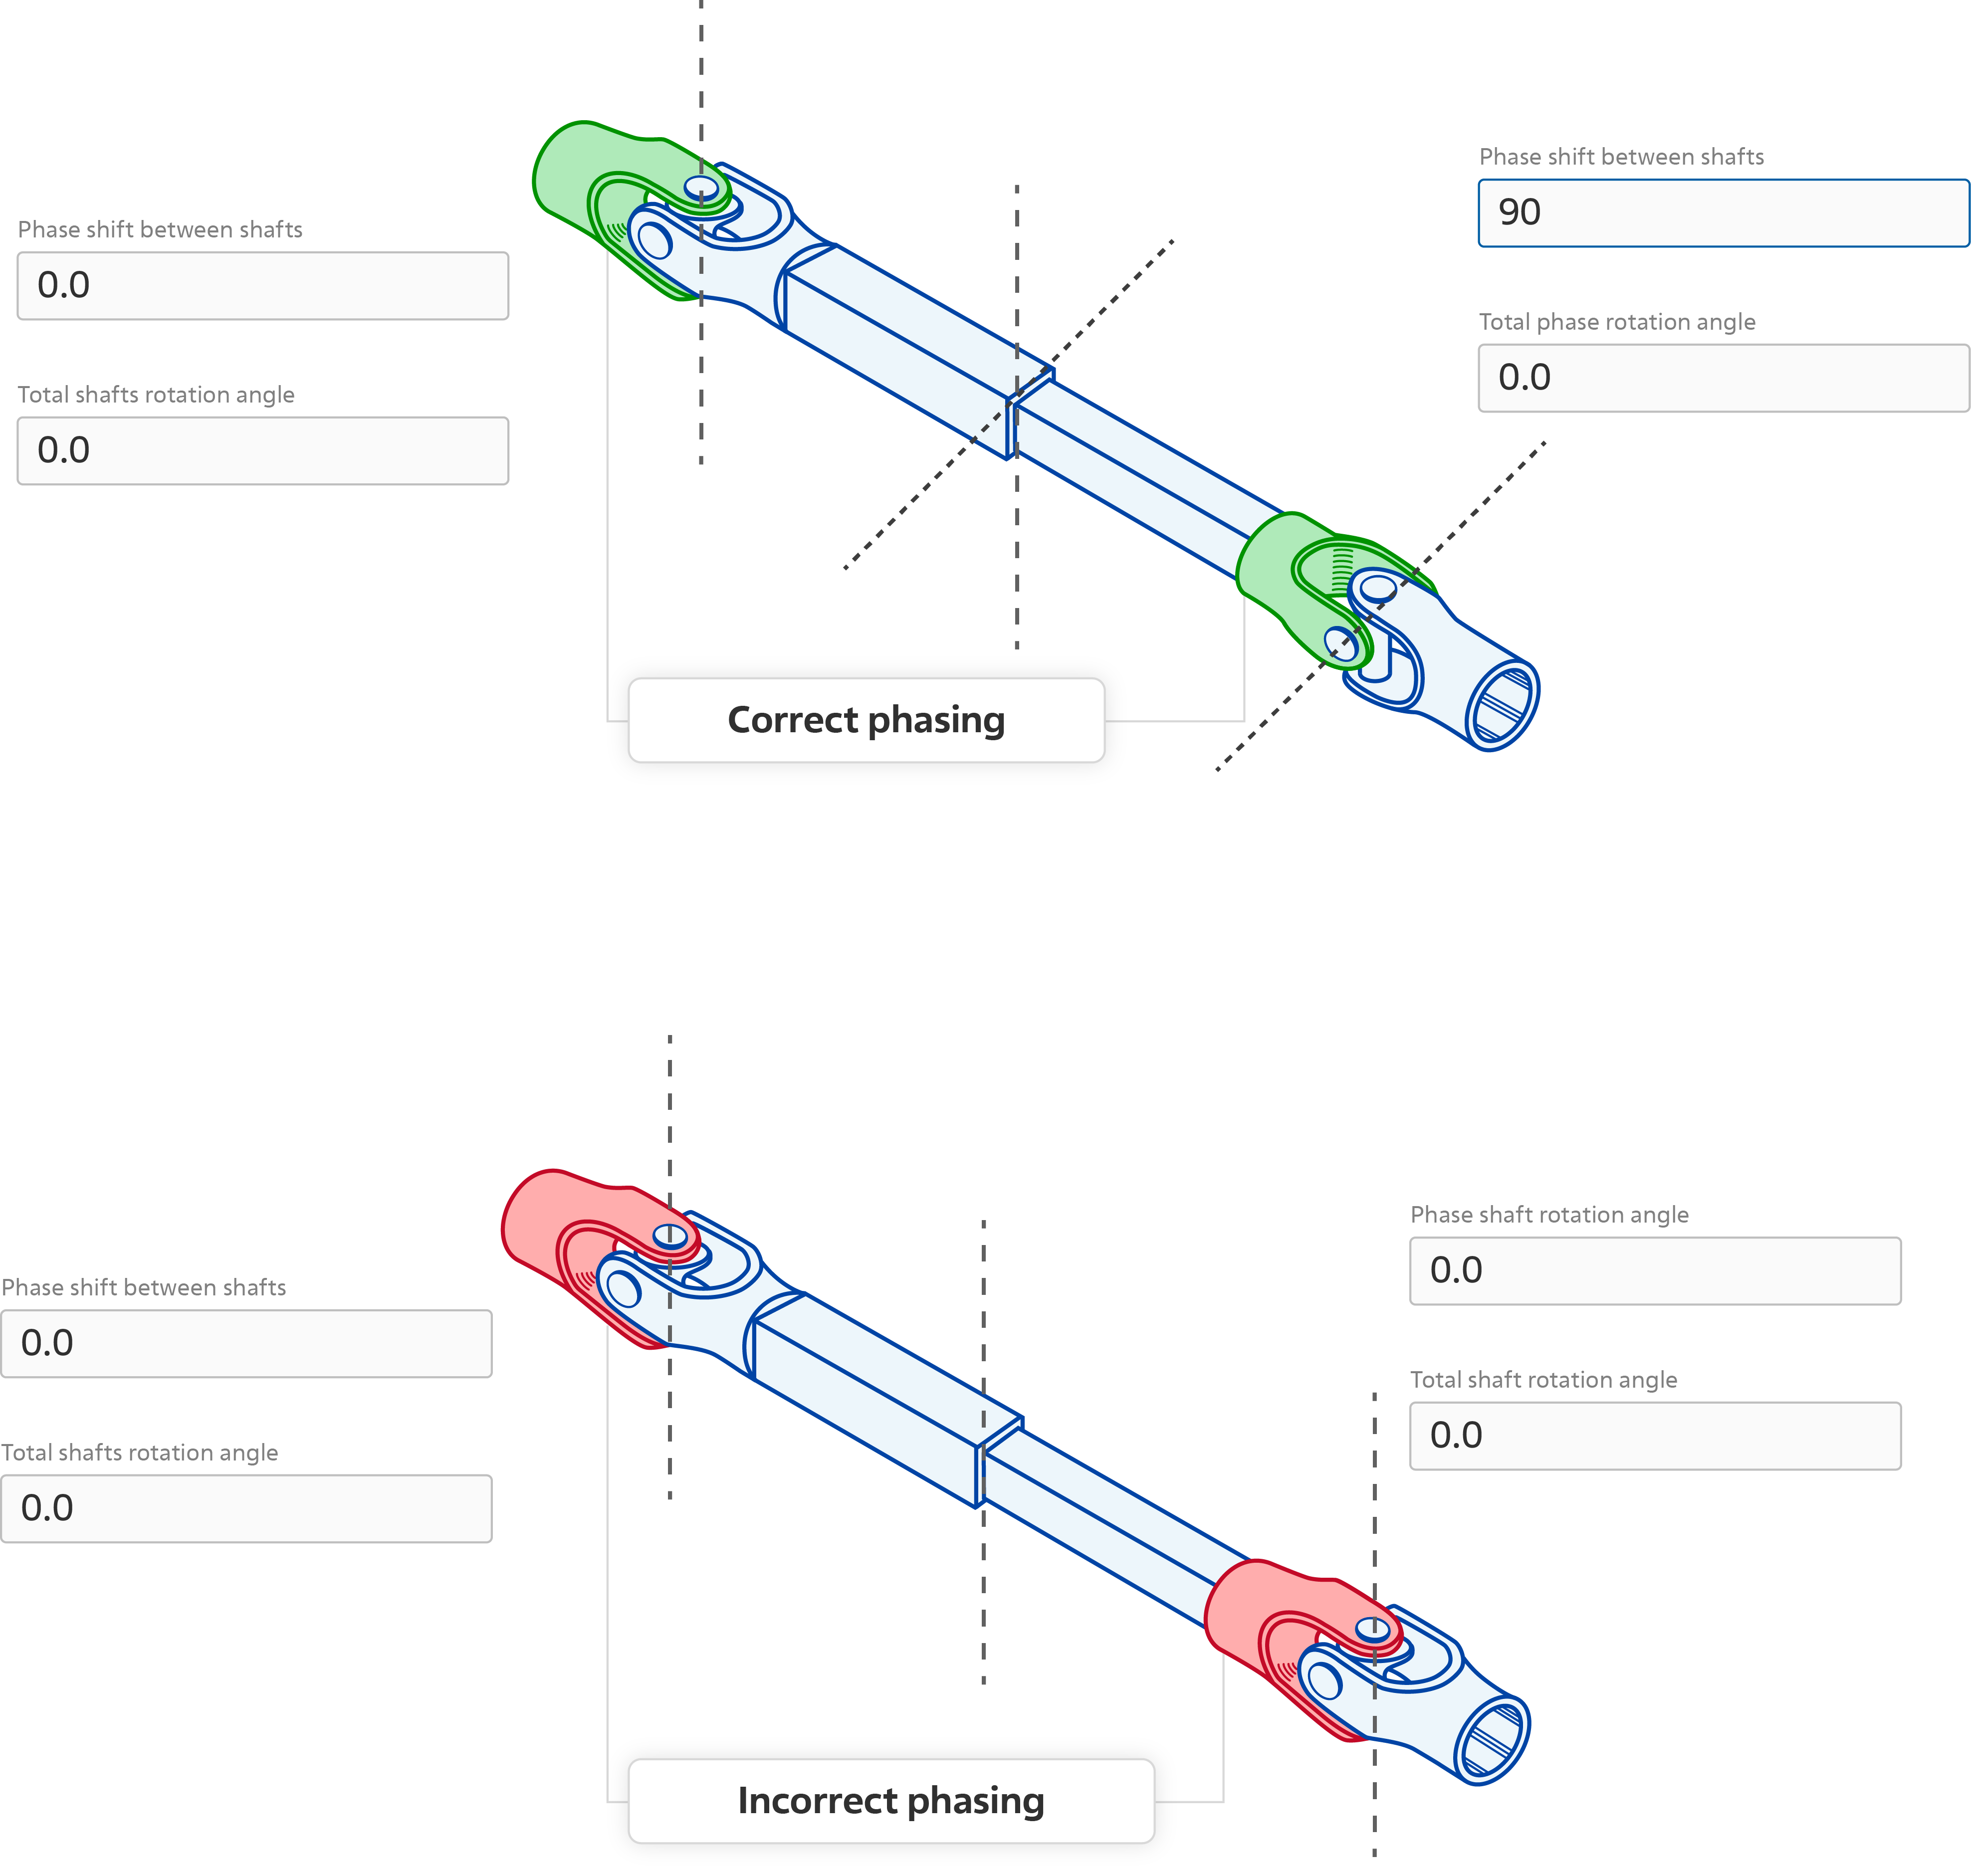
Fig. 2 Example of drive shaft#
1. Properties#
Property |
Default Value |
Description |
Units of measurement |
|---|---|---|---|
0.0 |
- |
deg |
|
0.0 |
- |
deg |
|
Switch between torque and angular velocity: |
Off |
- |
- |
2. Inputs and outputs#
Parameters |
Input/Output |
Description |
Units of measurement |
Port type |
|---|---|---|---|---|
Angle |
Input |
- |
deg |
Automation |
Angular velocity |
Input |
Available when |
\(\frac{rad}{s}\) |
Rotational motion |
Angular velocity |
Output |
Available when |
\(\frac{rad}{s}\) |
Rotational motion |
Torque |
Input |
Available when |
N\(\cdot\)m |
Rotational motion |
Torque |
Output |
Available when |
N\(\cdot\)m |
Rotational motion |
In order to see the connection capabilities of the block, you need to go to page Description of block ports