

Four-wheel car dynamics#
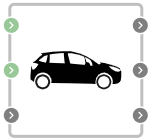
Block appearance in REPEAT VISION#
The Four-wheel car dynamics block simulates a vehicle driven in longitudinal motion by forces:
Resistance to tire movement \(F_{R,i}\);
Aerodynamic resistance \(F_{D}\);
Gravity \(F_{W}\);
Forces of front and rear axle \(F_{T,f}\), \(F_{T,r}\).
Then the general equation of the vehicle force (1):
The forces of the front and rear axle \(F_{T,f}\), \(F_{T,r}\) , are set to the first two ports on the right side.
The force of resistance to tire movement is calculated by the formula (2):
where
\(C_{R}\) - rolling coefficient;
\(F_{N,i}\) - force acting on either the front or rear transmission axle and equal to (3):
\(L_{101}\) - wheelbase length, [m];
\(F_{N,f}\), \(F_{N,r}\) - forces acting on the front and rear axles of the vehicle transmission, respectively, [N];
\(CG_{h}\) - height of mass center, [m]
\(CG_{f}\), \(CG_{r}\) - distances from the rear and front axle to the center of mass, [m].
The aerodynamic resistance force is calculated by the formula (4):
where
\(\rho\) - air density, [kg/m\(^3\)];
А - frontal area of electric vehicle, [m\(^2\)];
\(C_{D}\) - aerodynamic resistance coefficient;
V - longitudinal speed of the vehicle, [m/s].
The gravity force is calculated by the formula (5):
where
g - free fall acceleration, [m\(^2\)/s];
\(\theta\) - tilt angle, [deg];
m - mass of transport, [kg].
1. Properties#
Property |
Default value |
Description |
Units of measurement |
|---|---|---|---|
Wheelbase length |
2.7 |
- |
m |
Height of mass center |
0.4 |
- |
m |
Distance from rear axle to center of mass |
1.4 |
- |
m |
Distance from front axle to center of mass |
1.3 |
- |
m |
Free fall acceleration |
9.81 |
- |
m/s\(^2\) |
Car mass |
1540.0 |
- |
kg |
Frontal area |
2.4 |
- |
m\(^2\) |
Air density |
1.2 |
- |
kg/m\(^3\) |
Braking coefficient |
0.27 |
- |
- |
Rolling coefficient |
0.009 |
- |
- |
Velocity threshold |
1e-4 |
- |
m/s |
Off |
- |
- |
|
Wheel inertia, available when selecting |
0.3 |
- |
kg\(\cdot m^2\) |
Wheel radius, available when selecting |
0.32 |
- |
m |
2. Inputs and outputs#
Parameters |
Input/Output |
Description |
Units of measurement |
Port type |
|---|---|---|---|---|
Force on the front axle |
Input |
- |
N |
Translational motion |
Force on the rear axle |
Input |
- |
N |
Translational motion |
Vertical deviation angle |
Input |
- |
rad |
Automation |
Displacement |
Output |
- |
m |
Automation |
Overall resistive force |
Output |
- |
N |
Automation |
Speed |
Output |
- |
km/h |
Automation |
In order to see the connection capabilities of the block, you need to go to page Description of block ports