

Synchronous Machine#
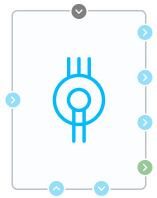
Block appearance in REPEAT VISION#
The Synchronous Machine block is a model of an electric three-phase synchronous motor with distinct poles.
The motor model contains two types of windings:
stator windings, which are three windings shifted by 120\(^о\) relative to each other;
rotor winding, which is an excitation winding and rotates together with the rotor;
Model description
The main part of the calculations takes place in the d-q-0 system, for which the following transformations and calculations are carried out:
where:
\(i_A, i_B, i_C\) – instantaneous current values in the respective stator phases, [A];
\( heta_e\) – electric angle of rotor rotation, [rad].
where:
\(L_{sd}, L_{sq}\) – self-inductances of stator windings in projections on d-q axis, [H];
\(i_f\) – instantaneous value of current in the excitation winding, [A];
\(L_{mf}\) – mutual inductance between excitation winding and stator windings in axis d, [rad].
Note
The model assumes that axis d coincides with the axis of the excitation winding
where:
\(L_{s0}\) – self-inductance of stator windings in zero projection, [H];
\(\omega_e\) – electric angular rotation rate, [rad/s], which is determined by the formula (9):
where:
\(\omega_r \) – angular rotor rotation rate, [rad/s];
p – number of pairs of rotor poles.
The following calculations are performed in the three-phase system of stator windings:
where:
\(R_s\) – active resistance of one stator phase, [Ohm];
\(L_{sA}, L_{sB}, L_{sC}\) – self- inductance of the respective stator phase, [H].
Note
This inductance varies in accordance with the angle of rotor rotation and is determined by the formulas (16), (17), (18):
where:
\(L_{aa0}\) – constant component of stator winding intrinsic inductance, [H];
\(L_{aa2}\) – variable component of stator winding intrinsic inductance, [H].
The self-inductance components of the stator winding are determined by the following formulas (19), (20):
The excitation winding voltage equation is as follows (21):
where:
\(R_f\) – active resistance of the excitation winding, [Ohm];
\(L_f\) – self-inductance of excitation winding, [H].
The electromagnetic torque on the motor shaft is determined by the formula (22):
Motor mechanical equation is as follows (23):
where:
\(J_Я\) – moment of inertia of the rotor, [Н\(\cdot\)m\(^2\)];
\(M_{res}\) – moment of resistance created by mechanical load on the rotor shaft, [Н\(\cdot\)m];
\(M_{fr}\) – friction torque, determined by friction in bearings and brushes, Н\(\cdot\)m. This torque is determined by the formula (24):
where \(K_{fr}\) – friction factor.
1. Properties#
Property |
Default Value |
Description |
Units of measurement |
|---|---|---|---|
Number of pole pairs |
4.0 |
– |
un. |
Active resistance of stator winding |
0.08 |
– |
Ohm |
Stator inductance of the d-axis |
0.00015 |
– |
H |
Stator inductance of the q-axis |
0.00021 |
– |
H |
Mutual inductance between the field winding and the d-axis stator winding |
0.007 |
– |
H |
Stator inductance of zero sequence |
0.000012 |
– |
H |
Main field resistance |
3.0 |
– |
Ohm |
Inductance of the main field winding |
0.5 |
– |
H |
Moment of inertia of rotor |
0.01 |
– |
kg\(\cdot\)m\(^2\) |
Rotor friction coefficient |
0.01 |
– |
Н\(\cdot\)m/(rad/sec) |
Array of initial conditions [IF, w, \( heta\)] |
0.0; 0.0; 0.0 |
– |
A; rad/s; rad |
On |
– |
– |
2. Inputs and outputs#
Parameters |
Input/Output |
Description |
Units of measurement |
Port type |
|---|---|---|---|---|
Load torque |
Input |
Value of shaft moment due to load |
N\(\cdot\) m |
Automation |
N, available when |
Input |
Zero point of stator windings |
- |
Electronics |
+ОВ |
Input |
Excitation winding positive lead |
- |
Electronics |
Angular frequency |
Output |
Gets connected to angular velocity ports of blocks from the library Mechanics/Rotational motion |
rad/s |
Rotational motion |
+A |
Output |
Phase A winding positive lead |
- |
Electronics |
+B |
Output |
Phase B winding positive lead |
- |
Electronics |
+C |
Output |
Phase C winding positive lead |
- |
Electronics |
-ОВ |
Output |
Excitation winding negative lead |
- |
Electronics |
A-, available when |
Input |
Phase A winding negative lead |
- |
Electronics |
B-, available when |
Input |
Phase B winding negative lead |
- |
Electronics |
C-, available when |
Input |
Phase C winding negative lead |
- |
Electronics |
In order to see the connection capabilities of the block, you need to go to page Description of block ports