

PLL (1 phase)#
Block appearance in REPEAT VISION#
Block PLL (1 phase) implements the phase frequency autotuning loop (PLL) receiving a single-phase input signal.
The block is based on the standard structure of the single-phase PLL[1], its block diagram is given in Fig. 1.
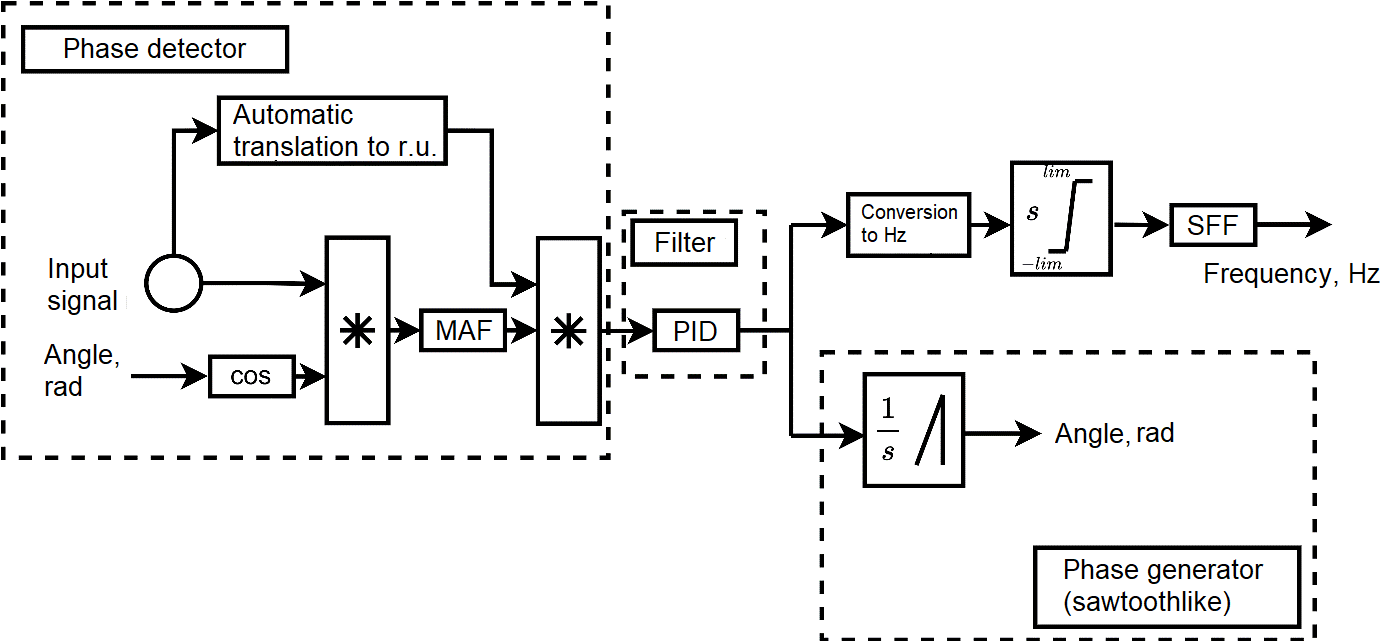
Fig. 1 Block diagram of single-phase PLL#
Note
This model is designed to calculate the frequency and phase of the input sinusoidal signal
Model consists of the following functional parts:
Phase detector. Generates phase difference signal of input sinusoid and phase generator. Also, the block implements the possibility of filtering the phase difference signal using the Moving Average Filter (MAF). It can be activated via
Moving average
Important
A signal in relative units is expected at the input.
Note
In the block, it is possible to implement automatic transfer of the signal from named units to relative ones by multiplying by a coefficient calculated from the input signal module. To enable such functionality, the block provides the property Adaptive gain.
Filter. It is a PID controller that generates a signal based on the phase difference determined by the phase detector. In fact, this signal is the frequency of the input sinusoid in \(\frac{rad}{s}\). In this case, the initial value of this frequency is set in the
Initial frequency. The block diagram of this controller implementation in the block is given in Fig. 2.
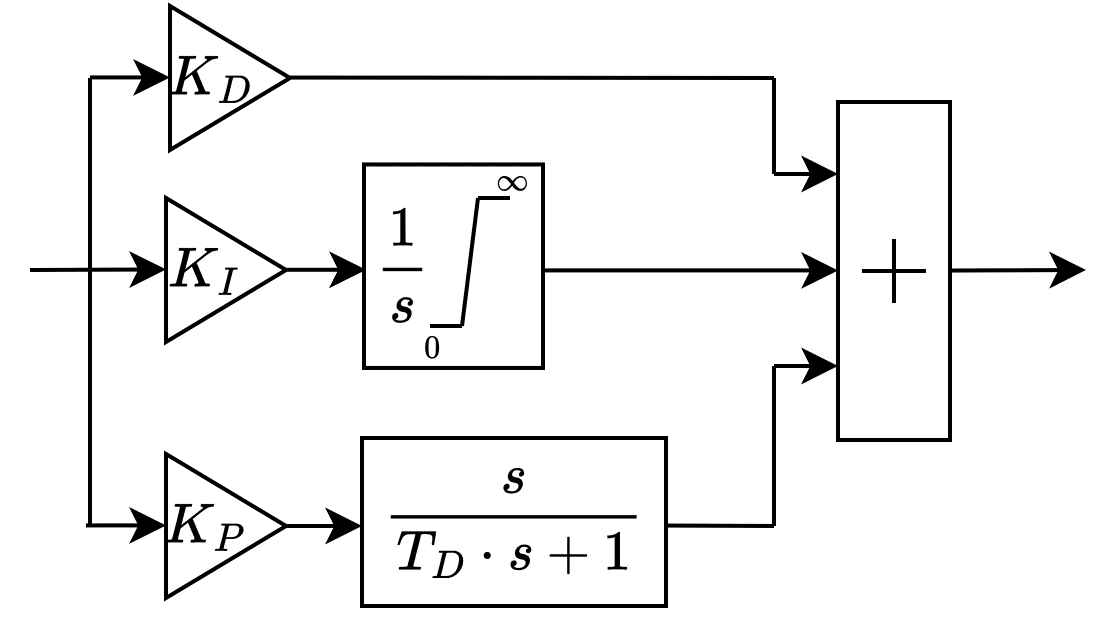
Fig. 2 The block diagram of PID controller implementation#
Note
In the PID controller design, a low-pass filter described by a first-order transfer function is implemented in the differential channel. The filter time constant is specified in the ‘Derivative filter time constant`.
Phase generator (sawtoothlike). It is an integrator that resets when the phase reaches a value of \(2\cdot\pi\) and thus forms a sawtoothlike signal at the output. Control signal from PID controller is transmitted to input of this unit.
The input frequency is determined from the PID controller output signal. In its simplest form, it is determined by transferring this signal from \(\frac{rad}{s}\) to Hz. The block implements the ability to enable the limitation of the rate of change of the signal, as well as its filtering after limitation. Use ROCOF limiter and Frequency filter properties to enable this functionality.
1. Properties#
Property |
Default Value |
Description |
Units of measurement |
|---|---|---|---|
Minimum frequency, available if |
45.0 |
- |
Hz |
Initial phase |
0.0 |
- |
deg |
60.0 |
- |
Hz |
|
Proportional gain |
180.0 |
- |
- |
Integral gain |
3200.0 |
- |
- |
Derivative gain |
1.0 |
- |
- |
0.01 |
- |
s |
|
Frequency filter cut-off frequency, available when |
100.0 |
- |
Hz |
ROCOF limit, available when |
1000.0 |
- |
- |
On |
- |
- |
|
On |
- |
- |
|
On |
- |
- |
|
On |
- |
- |
|
Sampling type: |
Fundamental project frequency decimation |
- |
- |
Sample time, available when selecting |
0.05 |
- |
s |
Decimation factor of project fundamental discretization frequency, available when selecting |
1 |
- |
- |
Sampling frequency, available when selecting |
20.0 |
- |
Hz |
2. Inputs and outputs#
Parameters |
Input/Output |
Description |
Units of measurement |
Port type |
|---|---|---|---|---|
Input signal |
Input |
- |
- |
Automation |
Frequency |
Output |
- |
Hz |
Automation |
Angle |
Output |
- |
rad |
Automation |
In order to see the connection capabilities of the block, you need to go to page Description of block ports