

Damper#
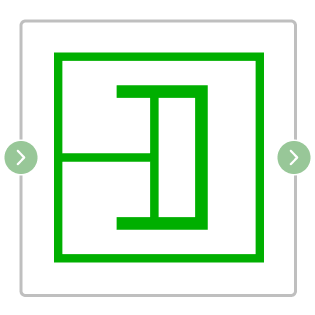
Block appearance in REPEAT VISION#
The block implements a mathematical model of an ideal viscous damper with a constant dampingcoefficient described by the following equation (1):
(1)#\[
F=D\cdot\left(V_R-V_C\right)
\]
where:
\(F\left(t\right)\) - damping force, [N];
\(D\) - damping factor, [N \(\cdot \) s/m];
\(V_R\left(t\right)\) - R port speed, [m/s];
\(V_C\left(t\right)\) - C port speed, [m/s].
1. Properties#
Property |
Default value |
Description |
Units of measurement |
|---|---|---|---|
Damping factor |
1.0 |
- |
N \(\cdot \) s/m |
2. Inputs and outputs#
Parameters |
Input/Output |
Description |
Units of measurement |
Port type |
|---|---|---|---|---|
Velocity port |
Input |
Speed of the first block |
m/s |
Translational motion |
Translational force |
Output |
- |
N |
Translational motion |
In order to see the connection capabilities of the block, you need to go to page Description of block ports