

Rotary moment of inertia with friction#
Block appearance in REPEAT VISION#
The Rotary moment of inertia with friction block model provides a solution to the equation of motion of a rotating body with constant inertia (1) :
where:
J - moment of inertia, [kg\(\cdot\)m\(^2\)];
\(\omega\) - angular velocity, [rad/s];
T\(_{total}\) - total rotational (torque) moment, [N \(\cdot\) m];
T\(_{visc.}\) - viscous friction moment, [Н \(\cdot\)m];
T\(_{slid.}\) - sliding friction moment, [Н \(\cdot\) m];
T\(_{head.res.}\) - moment of head resistance, [Н \(\cdot\) m].
The input receives the moment signal in [N \(\cdot\) m], and the output transmits the angular velocity signal in [rad/s], see Fig. 1:
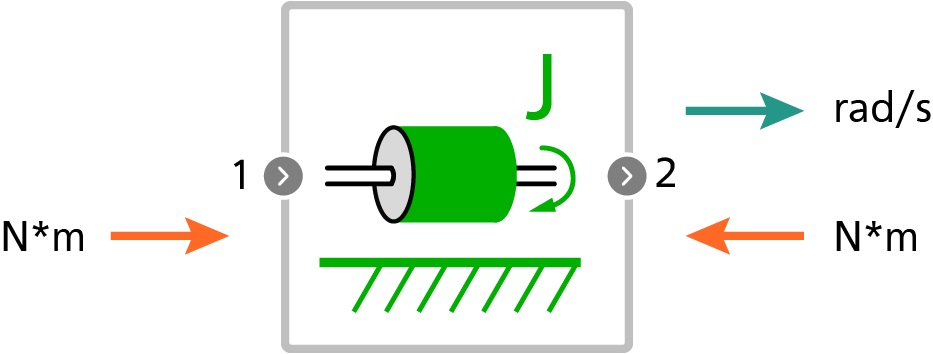
Fig. 1 Rotary moment of inertia with friction block icon#
The plot of friction moment versus angular velocity is shown in Fig. 2:
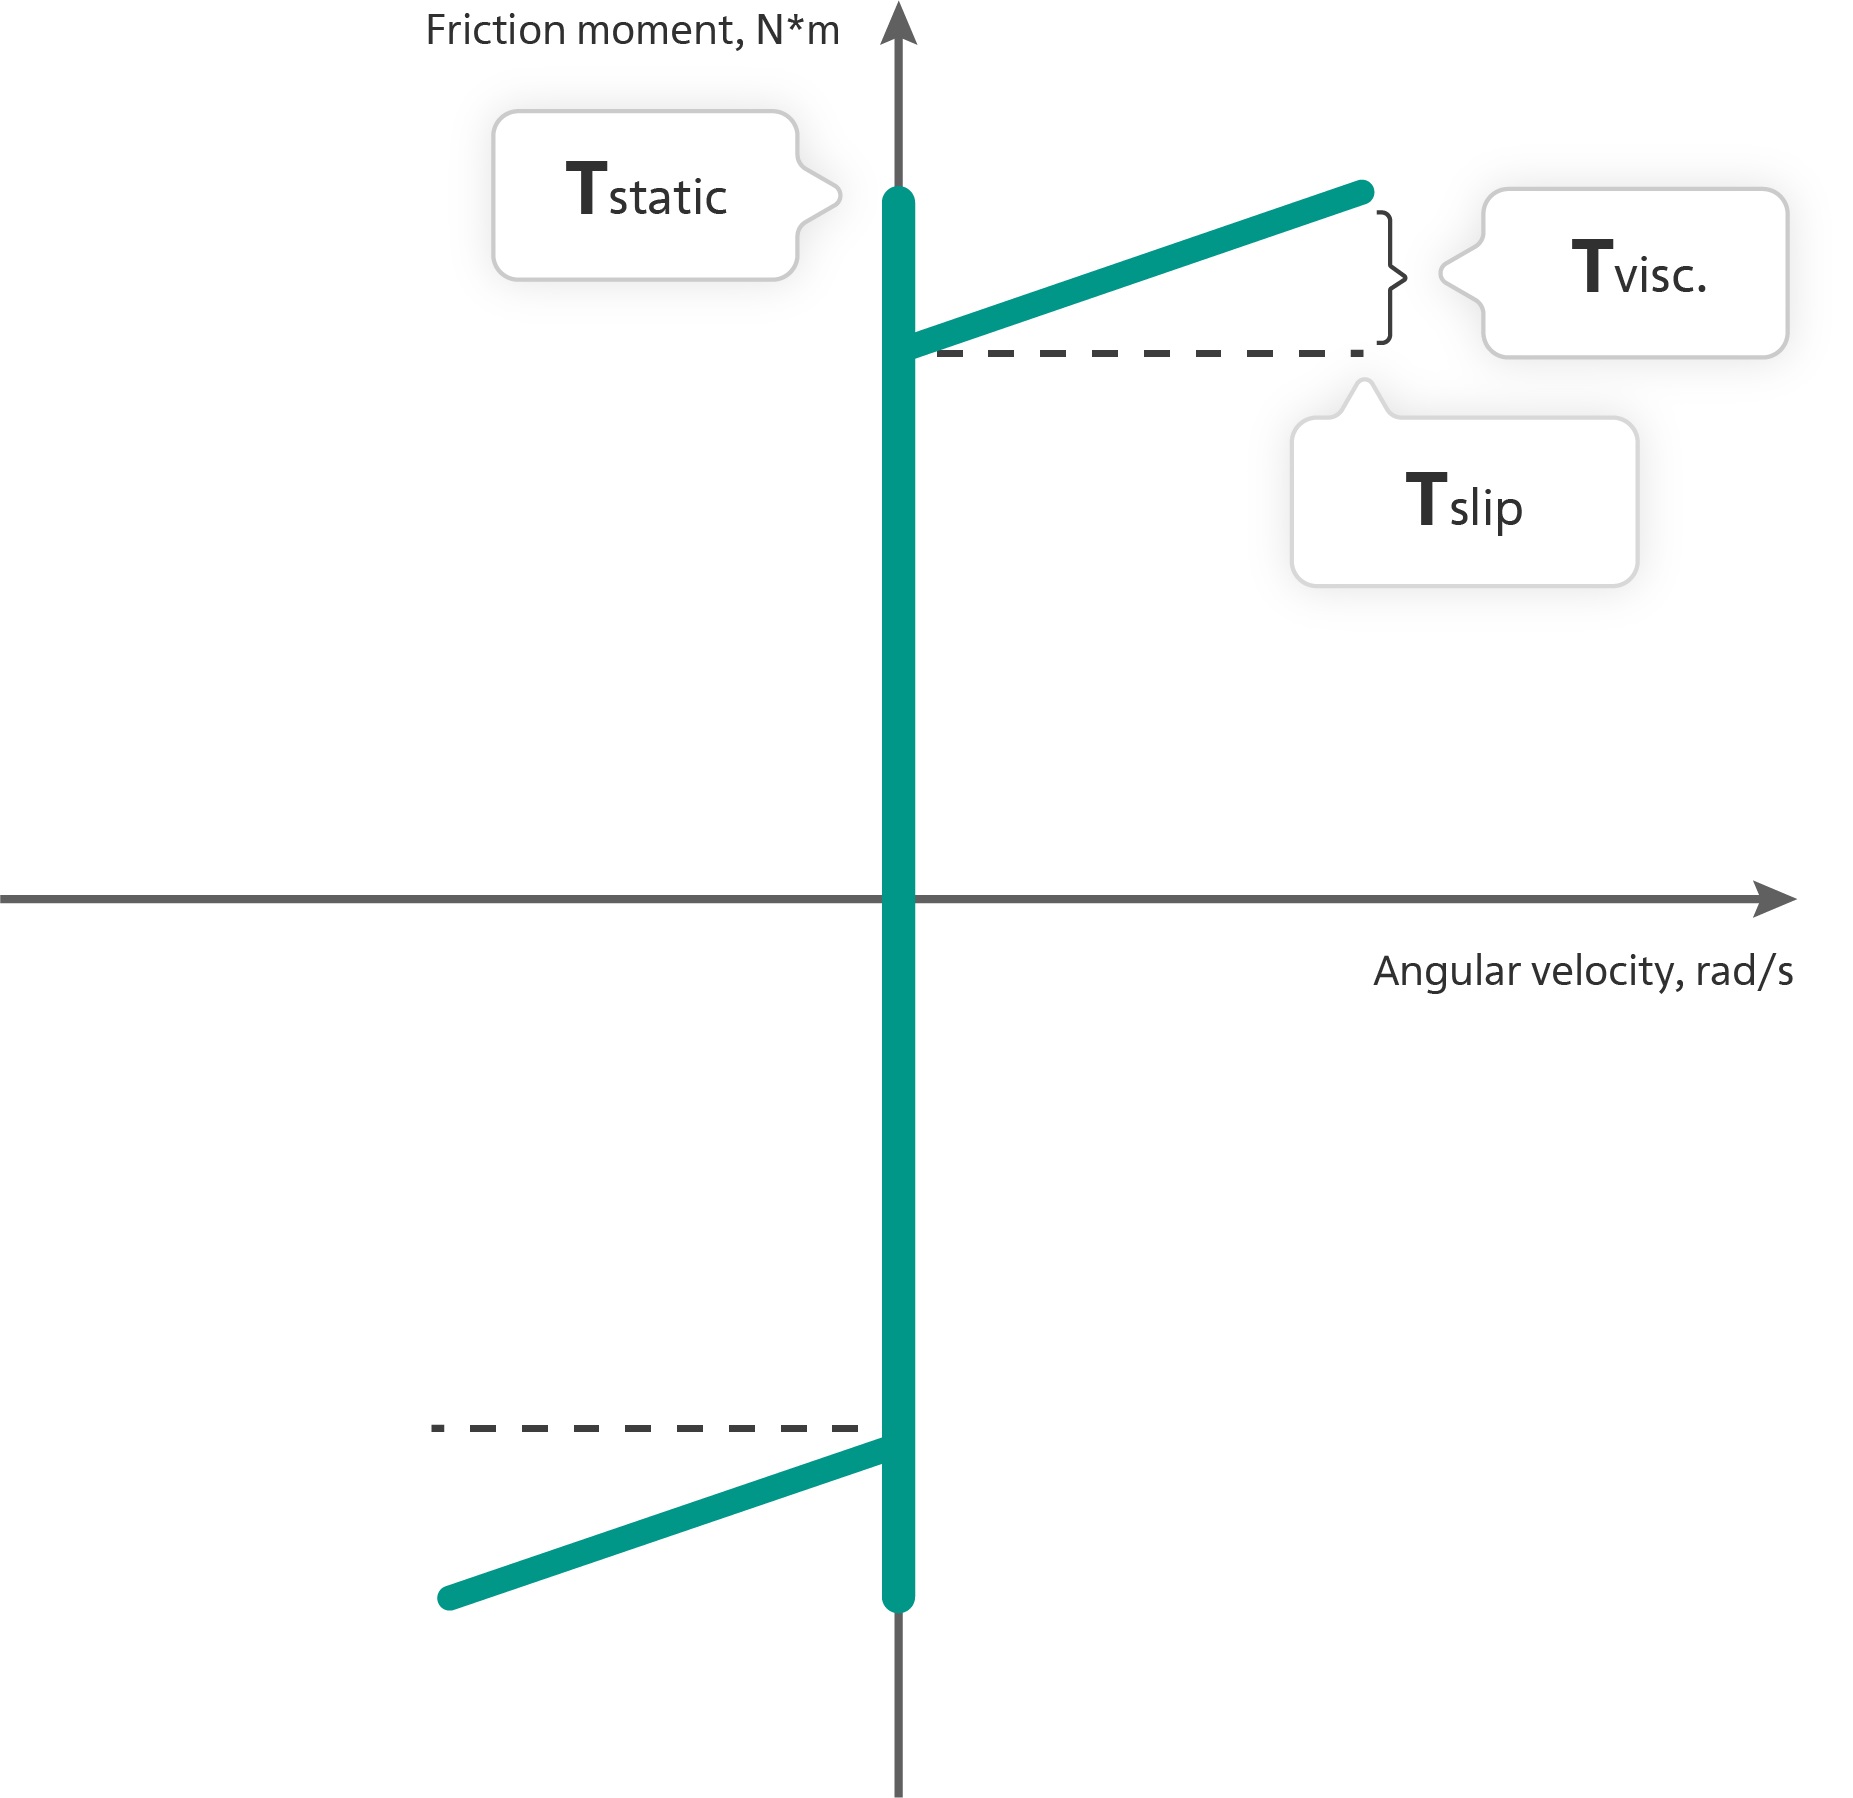
Fig. 2 Dependence of friction moment on angular velocity#
The moment of static friction, T\(_{static.}\) is the maximum moment that occurs during the transition from the rest state to sliding, when the modulus of the difference in moments supplied to the ports of the unit does not exceed the value of static friction, the body is at rest.
Sliding friction moment T\(_{slid.}\) occurs in sliding mode and has constant value.
Viscous friction moment T\(_{viscous.}\) is directly proportional to angular rotation frequency.
It is also possible to take into account the moment of friction of the drag T\(_{frac.}\), which depends on the square of the angular velocity.
It is important to note that the values represented by friction moments cannot be negative, and the sliding friction moment cannot be less than the resting friction moment.
1. Properties#
Property |
Default value |
Description |
Units of measurement |
|---|---|---|---|
Rotary moment of inertia |
1.0 |
- |
kg \(\cdot m^2\) |
Stiction torque |
1.0 |
- |
N·m |
Couloumb friction torque |
0.5 |
- |
N·m |
Viscous coefficient |
0.1 |
- |
N \(\cdot\) m/(rad/s) |
Windage coefficient |
0.0 |
- |
N \(\cdot\) m/\((rad/s)^2\) |
Off |
- |
- |
|
Initial angular velocity, available when selecting |
0.0 |
- |
rad/s |
2. Inputs and outputs#
Parameters |
Input/Output |
Description |
Units of measurement |
Port type |
|---|---|---|---|---|
Torque |
Input |
- |
N·m |
Rotational motion |
Angular velocity |
Output |
- |
rad/s |
Rotational motion |
In order to see the connection capabilities of the block, you need to go to page Description of block ports