

Reference (translational)#
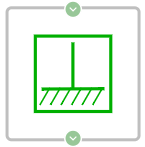
Block appearance in REPEAT VISION#
Reference (translational) block models a rigid connection to a fixed zero reference node that enforces zero velocity of any connected translational components.
The velocity at the reference point is always zero (1) :
where \(v (t)\) – is the velocity in [m/s].
All translational ports rigidly tied to the reference frame should be connected to this block.
Important
Do not connect Mass (or any other element already rigidly referenced to the frame) to zero reference — otherwise its velocity will be forced to zero.
1. Properties#
Property |
Default Value |
Description |
Units of measurement |
|---|---|---|---|
1 |
Sets the number of input ports for a block |
- |
|
1 |
Sets the number of output ports for a block |
- |
2. Inputs and outputs#
Parameters |
Input/Output |
Description |
Units of measurement |
Port type |
|---|---|---|---|---|
Input |
Input |
The number of input ports is specified in the |
- |
Translational motion |
Output |
Output |
The number of output ports is specified in the |
- |
Translational motion |
In order to see the connection capabilities of the block, you need to go to page Description of block ports