

Rotary friction#
Block appearance in REPEAT VISION#
The Rotary friction block simulates friction between two rotating bodies having a common rotation axis. The inertia moments of bodies are not taken into account.
The input and output port receive the angular velocity signal in [rad/s] (see Fig. 1 below), both transmit torque in [N \(\cdot\) m].
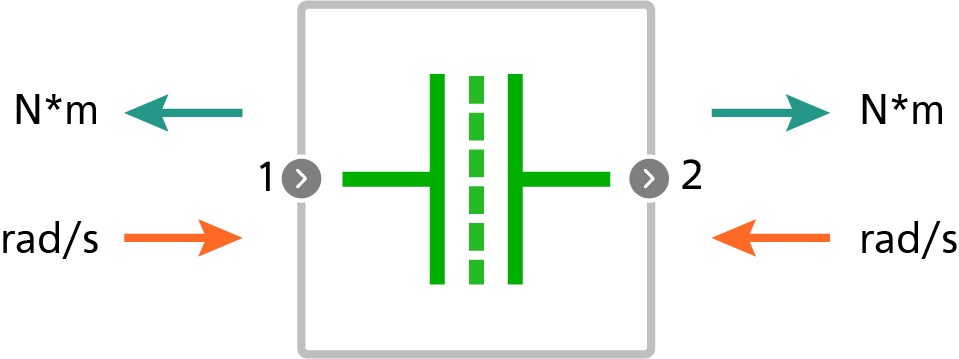
Fig. 1 Rotary friction block icon#
This block implements the “Integrator with reset” friction model, in which static friction depends on the accumulated angle of rotation between bodies, when overcoming the threshold angle, the friction model goes into sliding mode, Fig. 2:
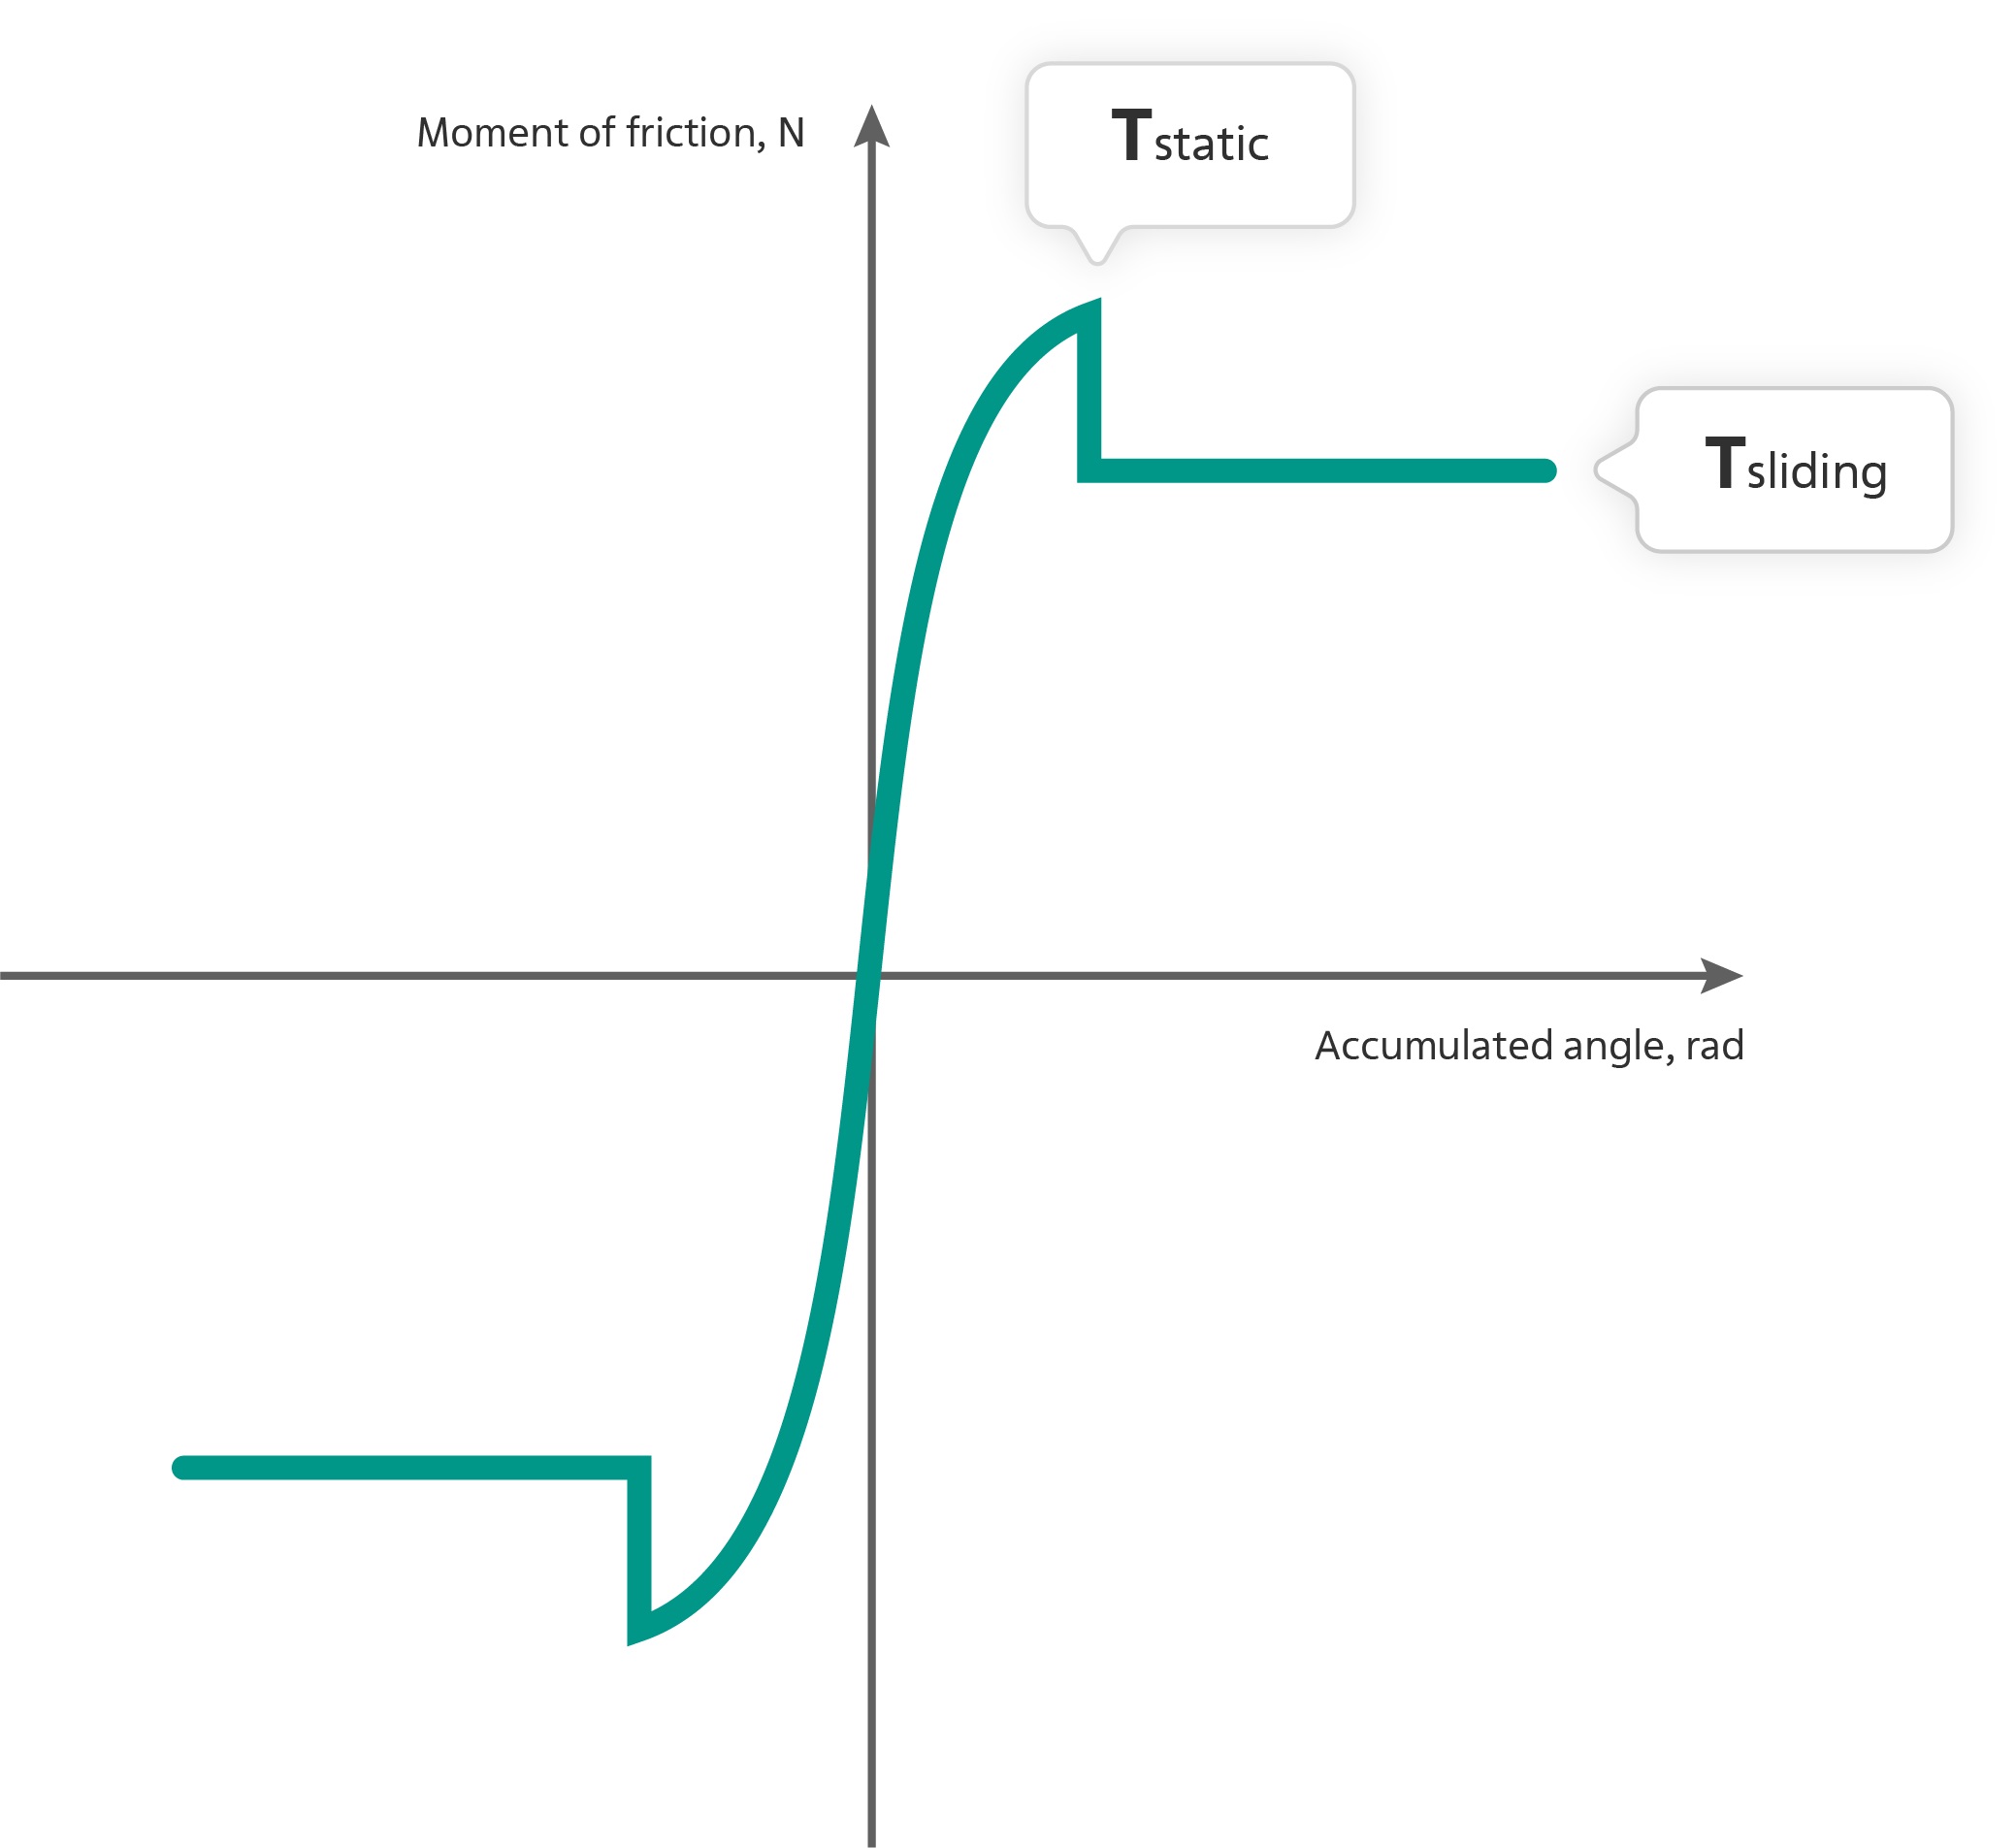
Fig. 2 Dependence of friction torque on accumulated relative angle#
The relative angular velocity is calculated by the formula (1):
where:
\(\omega_1\) - is the angular velocity of the left port, [rad/s];
\(\omega_2\) - is the angular velocity of the right port, [rad/s].
A negative angular frequency shall be applied to the right port for co-directional rotation.
At \( heta_{отн.}< heta_{порог.}\) (2) :
where:
\( heta_{rel.}\) - is the accumulated angle of rotation between bodies, [rad];
\(с_{visc}\) - coefficient of resilient friction (specified in block properties).
Hardness \(с_{hard}\). is determined by the formula (3):
When \( heta_{отн.}\geqslant heta_{порог.}\) the model switches to sliding mode at rest relativity, in which only sliding friction is taken into account (4) :
The accumulated angle is reset in sliding mode.
Important
Note that the static moment cannot exceed the sliding moment and their values cannot be negative.
1. Properties#
Property |
Default value |
Description |
Units of measurement |
|---|---|---|---|
Couloumb friction torque |
5.0 |
- |
N \(\cdot\) m |
Stiction friction torque |
5.0 |
- |
N \(\cdot\) m |
Stiction angle |
0.2 |
- |
deg |
1000.0 |
- |
N \(\cdot\) m/(rad/s) |
2. Inputs and outputs#
Parameters |
Input/Output |
Description |
Units of measurement |
Port type |
|---|---|---|---|---|
Angular velocity |
Input |
- |
rad/s |
Rotational motion |
Command signal |
Input |
- |
- |
Automation |
Torque |
Output |
- |
N \(\cdot\) m |
Rotational motion |
In order to see the connection capabilities of the block, you need to go to page Description of block ports