

Brushless direct current motor#
Block appearance in REPEAT VISION#
The Brushless direct current motor block is a model of a synchronous electric machine with a trapezoidal EMF shape and rotor position sensors.
The machine model is described by the following equations:
stator winding equations (1):
where:
\(i_A,i_B,i_C\) – current of phase A, B and C respectively, [A];
\(R\) – active resistance of the phase winding, [Ohm];
\(L\) – phase winding inductance, [H];
\(E_A,E_B,E_C\) – EMF of phase A, B and C respectively, [V].
where:
\(p\) – number of pole pairs;
\(k_e\) – design constant EMF, [V/(rad/s)];
\(\omega_r\) – angular frequency of rotor rotation, [rad/s];
\( heta_e\) – electrical angle of rotation of the rotor, [rad];
\(F\) is a function of EMF, which realizes a trapezoidal shape depending on the electrical angle of rotation of the rotor, shown in Fig. 1:
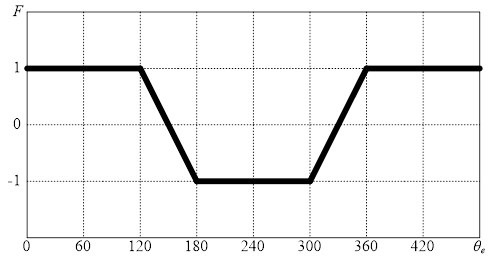
Fig. 1 Trapezoidal form of the EMF function#
electromagnetic torque on the shaft (3):
where \(k_t\) is the structural torque constant, [N\(\cdot\)m/A].
description of the mechanics of the engine (4):
where:
\(J_Я\) – moment of inertia of the anchor, [N\(\cdot\)m\(^2\)];
\(M_{вр}\) – electromagnetic torque on the armature shaft, [N\(\cdot\)m];
\(M_{тр}\) – friction moment, determined by friction in the bearings and brush-collector apparatus, [N\(\cdot\)m];
\(M_{сн}\) – the moment of resistance created by the load on the armature shaft, [N\(\cdot\)m].
Note
This value is supplied to the unit from the outside via the automation port and/or the mechanics port.
the friction moment is determined by the formula (5):
where \(K_{тр}\) is the friction coefficient.
1. Properties#
Property |
Default Value |
Description |
Units of measurement |
|---|---|---|---|
Number of pole pairs |
2.0 |
– |
– |
Winding active resistance |
2.875 |
– |
Ohm |
Winding inductance |
0.0027 |
– |
H |
Torque constant |
0.0042 |
– |
N\(\cdot\)m/А |
EMF constant |
0.0042 |
– |
V/(rad/s) |
Rotor inertia |
5.0E-4 |
– |
kg\(\cdot\)m\(^2\) |
Rotor friction coefficient |
8.9E-5 |
– |
N\(\cdot\)m/(rad/s) |
Initial Condition Array [rotor angular velocity, rotor angle] |
0.0; 0.0 |
– |
rad/s; rad |
On |
Changes the electrical circuit of the stator windings and the number of block terminals |
– |
2. Inputs and outputs#
Parameters |
Input/Output |
Description |
Units of measurement |
Port type |
|---|---|---|---|---|
Output torque |
Input |
The value of the external torque on the shaft from the load |
\(N\cdot m\) |
Automation |
A+ |
Input |
Beginning of phase A of the stator winding |
- |
Electronics |
A-, available when selecting |
Output |
End of phase A of the stator winding |
- |
Electronics |
B+ |
Input |
Start of phase B of the stator winding |
- |
Electronics |
B-, available when selecting |
Output |
End of phase B of the stator winding |
- |
Electronics |
C+ |
Input |
Start of phase C of the stator winding |
- |
Electronics |
C-, available when selecting |
Output |
End of phase C of the stator winding |
- |
Electronics |
N, available when selecting |
Output |
Neutral connection point of the windings |
- |
Electronics |
Angular velocity |
Output |
Connects to the angular velocity ports of blocks from the library Mechanics\Rotational motion |
rad/s |
Rotational motion |
In order to see the connection capabilities of the block, you need to go to page Description of block ports