

Induction motor (static model)#
Block appearance in REPEAT VISION#
Note
When adding a block to the canvas, a window appears with a choice of the required configuration, which allows you to:
Select a ready-made template with settings for a specific engine brand;
Select customizable configuration
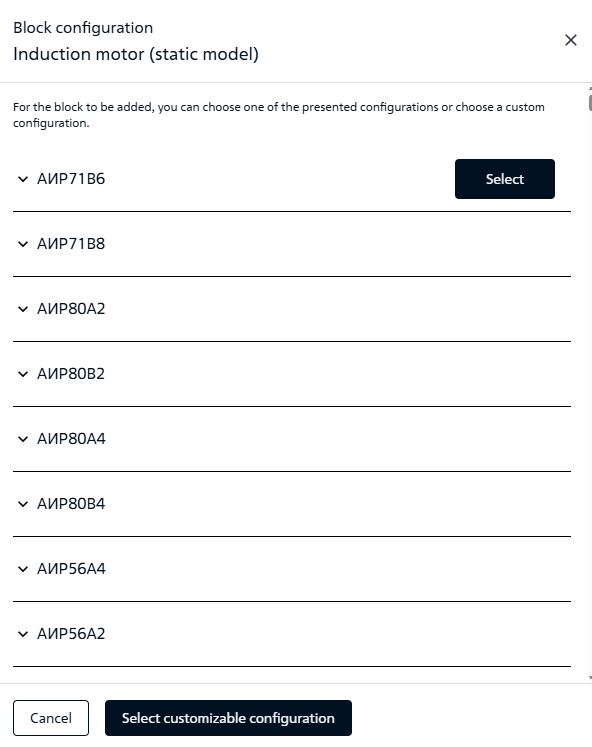
Configuration selection window#
This block is a static model of an asynchronous motor, the parameters of which are approximately calculated based on catalog data.
It shall be noted that this model is not capable of displaying electromagnetic transient processes and is designed to calculate the steady mode.
A number of assumptions are made when calculating the parameters:
The parameters are defined for an idealized machine in which the variables are \(β,γ,ϑ=1;\)
Rotary decrement \(ρr = const\);
Saturation is not considered;
\(x_k\:=\:r_k\:=\:0\) ;
\(s_v\:=\:0\) .
Model is based on motor equations in d, q axes (1):
where \(R_r\>=\>\frac{\rho_r\left(s\>-\ s_\nu\right)\mu x}{\rho_r^2\>+\>\left(s\>-\>s_\nu\right)^2\alpha_{sr}^2}\) and \( X_r\:=\:\frac{\alpha_{sr}(s\:-\: s_\nu)\mu x}{\rho^2 _r\:+\:(s\:-\: s_\nu)^2 \alpha ^2 _{sr}}\)
In the calculation process, the motor is represented by a shunt, resistance and, accordingly, the conductivity of which are described by formulas (2):
where \( R\:=\:(r+r_k)-(1+s_\nu)R_r\:,\:X\:=\:(1+s_{\nu})(\alpha_{sr} x\:+\:x_k\:-\:X_r)\).
The currents are then calculated by formulas (3):
The electromagnetic moment is calculated according to the formula (4):
where \(\eta_{нс}\:\:\) - is Efficiency taking into account losses not dissipated by the model.
It shall be noted that in this model, multiplicity value of maximum moment (overload capacity) Mmax shall be greater than 1, since the critical slip value is calculated using the Closs formula (5) :
1. Properties#
Properties |
Default value |
Description |
Units of measurement |
|---|---|---|---|
Rated voltage |
6 |
– |
kV |
Rated power |
100 |
– |
kW |
Rated slip |
0.02 |
– |
r.u. |
The maximum torque of the motor |
2.2 |
– |
r.u. |
The locked-rotor current |
5 |
– |
r.u. |
The locked-rotor torque |
1 |
– |
r.u. |
The motor time constant |
3 |
– |
s |
Rated power factor |
0.98 |
– |
r.u. |
Number of pole pairs |
1 |
- |
- |
Rated grid frequency |
50.0 |
- |
Hz |
Initial slip |
1.0 |
- |
r.u. |
[SC] R/X ratio |
0 |
For SC calculation |
- |
[SC] Rated efficiency |
0 |
For SC calculation |
% |
2. Inputs and outputs#
Parameters |
Input/Output |
Description |
Units of measurement |
Port type |
|---|---|---|---|---|
Voltage |
Input |
- |
r.u. |
Electrocity |
Load torque |
Input |
- |
r.u. |
Automatics |
Angular speed |
Output |
- |
r.u. |
Rotational motion |
Motor torque |
Output |
- |
r.u. |
Automatics |
Motor current |
Output |
- |
r.u. |
Automatics |
In order to see the connection capabilities of the block, you need to go to page Description of block ports